WISEPORTX / ROBOTICS
IRUS-CTU
Dual-arm container twistlock removal robot
ENGINEERED IN EVERY DETAIL
One container, four stations, eight coordinated arms
A dual-arm workcell at each of the four bottom corners, working in coordination around the container's corner castings.

Actual STEP model rendering · View demonstration only, not operation footage
Dual-arm container twistlock removal robot
From corner casting localization to twistlock removal, engineered mechanisms connect perception with execution.
Explore the productWISEPORTX / ROBOTICS
IRUS-CTU
Dual-arm coordination for real-world operations.
Dual-arm container twistlock removal robot
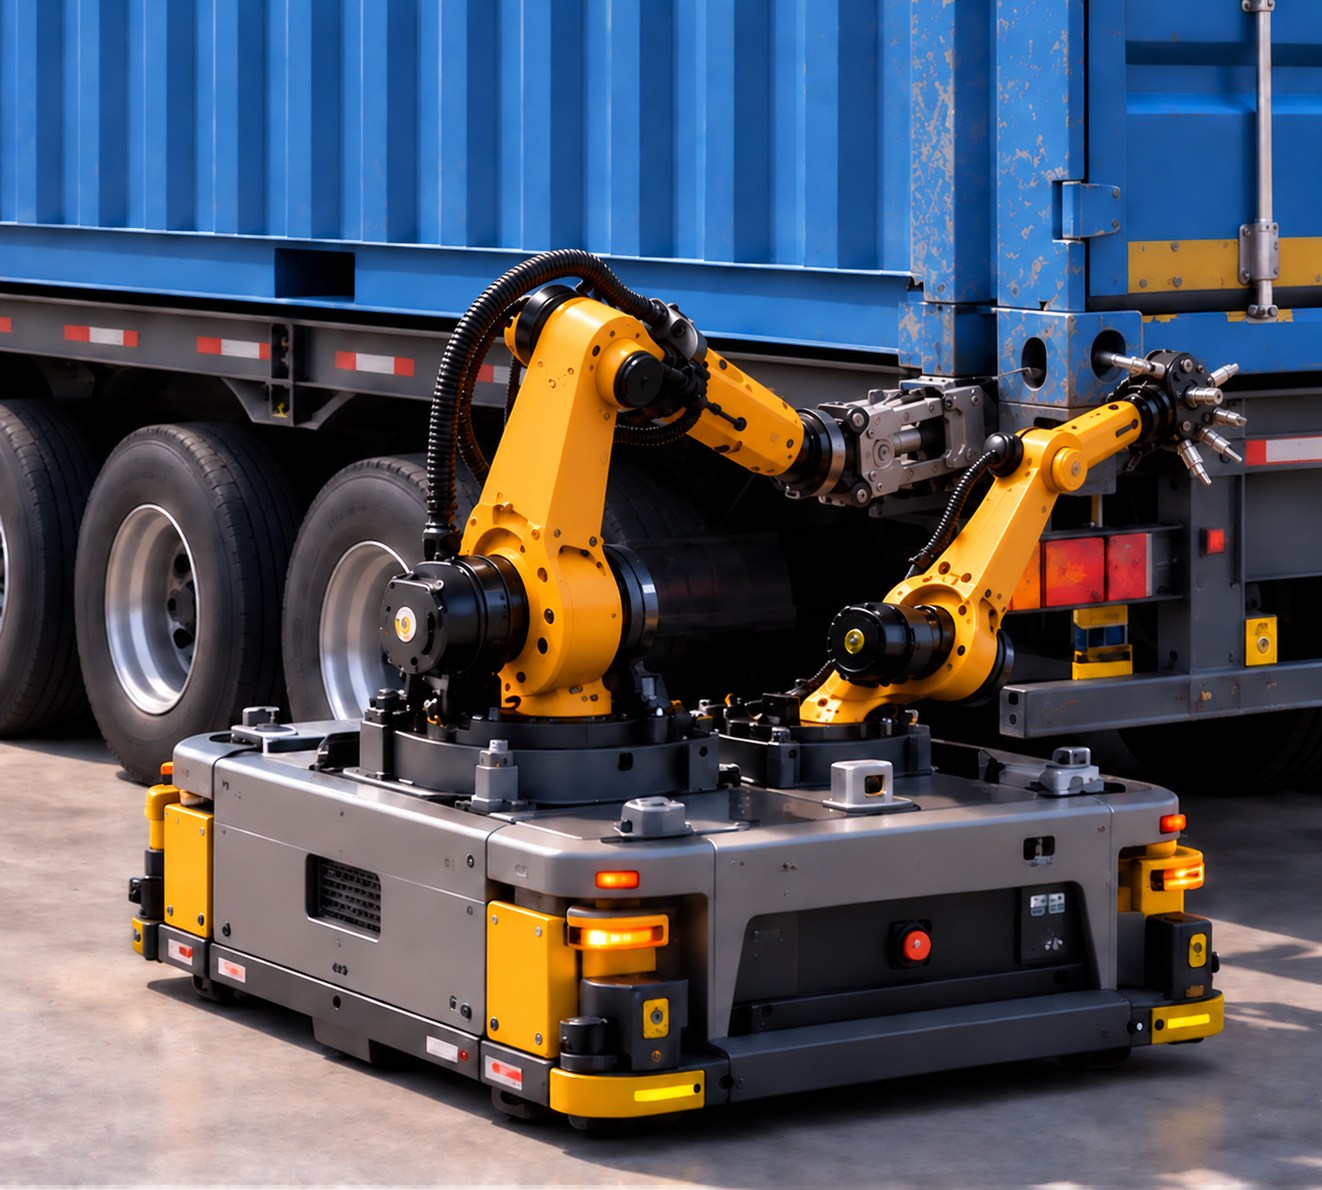
One container, four stations, eight coordinated arms
A dual-arm workcell at each of the four bottom corners, working in coordination around the container's corner castings.
Corner casting engagement
From corner casting localization to twistlock removal, engineered mechanisms connect perception with execution.
Designed for industrial worksites
Safety-oriented signal-orange finish designed for operations alongside container trucks.
OPERATION LOGIC / 01—06
IRUS-CTU six-step operating sequence
A complete closed-loop workflow built around a single twistlock removal task.
- 01In position
- 02Detection
- 03Positioning
- 04Unlocking operation
- 05Result verification
- 06Safe withdrawal
INITIAL VALIDATION SCOPE
Initial validation scope
Initial validation focuses on twistlock detection and positioning, the unlocking operation, and result feedback. Twistlock sorting, TOS integration, and all-weather reliability are reserved for subsequent engineering validation.
LET’S ENGINEER WHAT’S NEXT.